AgiBot
X2
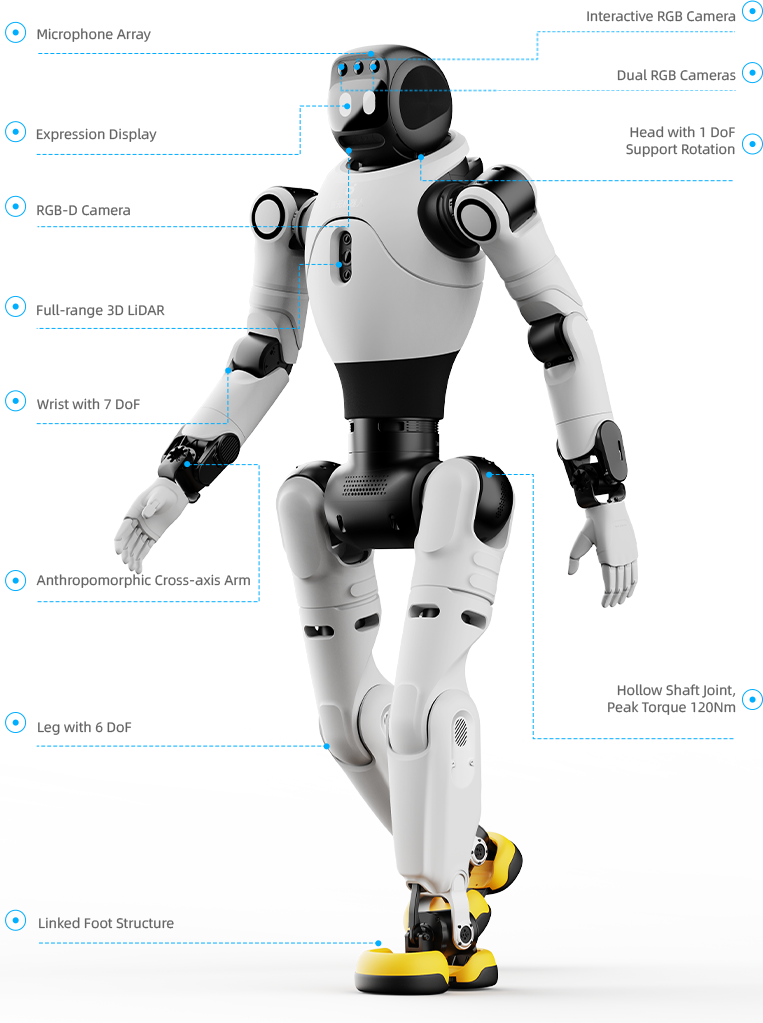
Bipedal humanoid robot, 1.31 m tall, with 30 degrees of freedom, 3D LiDAR, RGB-D vision and an NVIDIA Orin NX computer (157 TOPS). Built for hospitality, events, education and developing new applications.
Request a demo- Free advice before you buy
- Warranty and local support
- Delivery and setup agreed with you
Description
Overview
AgiBot X2 is a compact bipedal humanoid robot: 1.31 m tall and about 39 kg. It walks, gestures and interacts with people through voice, its screen and light effects. It suits hospitality, events and education, and has a dedicated computer for building custom applications.
Motion
- 30 degrees of freedom: 1 in the head, 7 in each arm, 3 in the waist, 6 in each leg.
- Peak joint torque of 120 N·m.
- Top speed of 1.8 m/s; up to 0.8 m/s in everyday use.
Perception
- Chest-mounted 3D LiDAR for a real-time map of the surroundings.
- RGB-D depth camera, front stereo camera, interaction camera and rear camera to reduce blind spots.
- Head touch sensor and two inertial sensors (chest and hip).
Interaction
Microphone array, wireless microphone, speakers, interactive screen and light effects.
Development and software
- NVIDIA Jetson Orin NX 16 GB (157 TOPS) development computer, separate from the motion-control computer.
- AimDK development kit, LinkCraft platform, mobile app, handheld controller and OTA updates.
- WiFi, Bluetooth and 4G/5G connectivity.
Battery
About 421 Wh battery: roughly 2 hours of continuous walking at 0.5 m/s, recharged in under 1.5 hours. Supports direct charging and battery swapping; automatic charging is optional.
Optional accessories
OmniPicker gripper, OmniHand, teleoperation accessories and charging station.
Technical specifications
| Height | 1.31 m |
|---|---|
| Dimensions (H × W × D) | 1310 × 460 × 210 mm |
| Weight | about 39 kg |
| Degrees of freedom | 30 (head 1, arms 2 × 7, waist 3, legs 2 × 6) |
| Arm span | 558 mm (without end-effector) |
| Peak joint torque | 120 N·m |
| Speed | max 1.8 m/s; everyday use ≤ 0.8 m/s |
| Payload | 3 kg in a specific posture; ≤ 1 kg across the full workspace (without end-effector) |
| Sensors | 3D LiDAR, RGB-D camera, front stereo, interaction camera, rear camera, touch sensor, 2 IMUs |
| Interaction | microphone array, wireless microphone, speakers, interactive screen, lights |
| Development computer | NVIDIA Jetson Orin NX 16 GB, 157 TOPS |
| Base computing | RK3588s + RK3588 |
| Connectivity | WiFi, Bluetooth, 4G/5G |
| Interfaces | 2 × USB-A, 2 × USB-C, 2 × RJ45 |
| Battery | about 421 Wh, swappable |
| Battery life | about 2 hours of continuous walking at 0.5 m/s |
| Charging time | ≤ 1.5 hours |
| Operating temperature | −10 °C to 40 °C |
See it in action
Videos are hosted on YouTube and load, in privacy-enhanced mode, only when you press play.